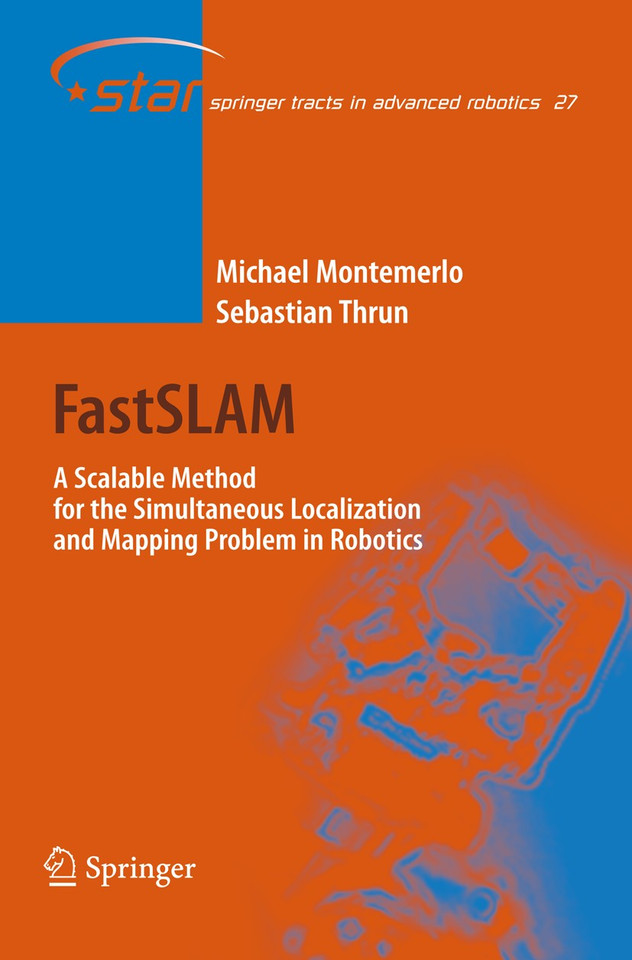
FastSLAM: A Scalable Method for the Simultaneous Localization and Mapping Problem in Robotics (Springer Tracts in Advanced Robotics #27)
Format
The more copies, the less each one costs
Applied automatically in your cart. No code needed.
Built for school and campus orders
PDF quotes, purchase orders, tax exemption and multi-site delivery, handled by one account manager.
FastSLAM
This monograph describes a new family of algorithms for the simultaneous localization and mapping problem in robotics (SLAM). SLAM addresses the problem of acquiring an environment map with a roving robot, while simultaneously localizing the robot relative to this map. This problem has received enormous attention in the robotics community in the past few years, reaching a peak of popularity on the occasion of the DARPA Grand Challenge in October 2005, which was won by the team headed by the authors. The FastSLAM family of algorithms applies particle filters to the SLAM Problem, which provides new insights into the data association problem that is paramount in SLAM. The FastSLAM-type algorithms have enabled robots to acquire maps of unprecedented size and accuracy, in a number of robot application domains and have been successfully applied in different dynamic environments, including the solution to the problem of people tracking.
The book, FastSLAM: A Scalable Method for the Simultaneous Localization and Mapping Problem in Robotics (Springer Tracts in Advanced Robotics #27) [Bulk, Wholesale, Quantity] ISBN#9783642079788 in Paperback by Michael Montemerlo, Sebastian Thrun may be ordered in bulk quantities. Minimum starts at 25 copies. Availability based on publisher status and quantity being ordered.
Details
- Publisher
- Springer Berlin Heidelberg
- Authors
- Michael Montemerlo, Sebastian Thrun
- Format
- Paperback
- Published
- Nov 18, 2010
- ISBN-13
- 9783642079788
- Pages
- 120
- Printing
- Printed on demand
FastSLAM in bulk: pricing
Volume pricing applies automatically in your cart. No codes, no account needed.
| Copies | Price per copy | You save |
|---|---|---|
| 25 – 49 | $96.79 | 12% off list |
| 50 – 99 | $95.69 | 13% off list |
| 100+ | $94.59 | 14% off list |
Popular for
A copy for every student in the class or section.
Shared reading for professional development.
Common reads and first-year programs.
How fast can I get copies of FastSLAM?
This title is printed on demand, so it needs production time before it ships. Need them by a specific date? Request a quote and we'll confirm timing before you pay.
Can you ship to several locations or people's homes?
Yes. We ship in bulk to one address, to multiple sites, or to individual recipients, in the US and internationally. See fulfillment options.
Can I get a formal quote for approval before ordering?
Yes. Request a quote and we'll send a PDF you can forward for approval.
Do you accept purchase orders and tax-exempt orders?
Yes. We accept purchase orders upon approval, as well as cards, PayPal, ACH, wire transfers and checks. BookPal is a tax-exempt supplier in all 50 states. See purchase orders and sales tax exemption.
What if I find a lower price?
Send us the link. We match prices from other bulk booksellers and distributors on a new copy in the same edition, available to ship in the quantity you need. Clearance sales and pricing errors are the exception, and we'll tell you quickly if that's the case. Start a price match.
What buyers say
Write a Review
FastSLAM: A Scalable Method for the Simultaneous Localization and Mapping Problem in Robotics (Springer Tracts in Advanced Robotics #27) [9783642079788]
Groups also order


A colleague asked you to approve this order
Your quote list
Add books as you browse, then request one quote for all of them.