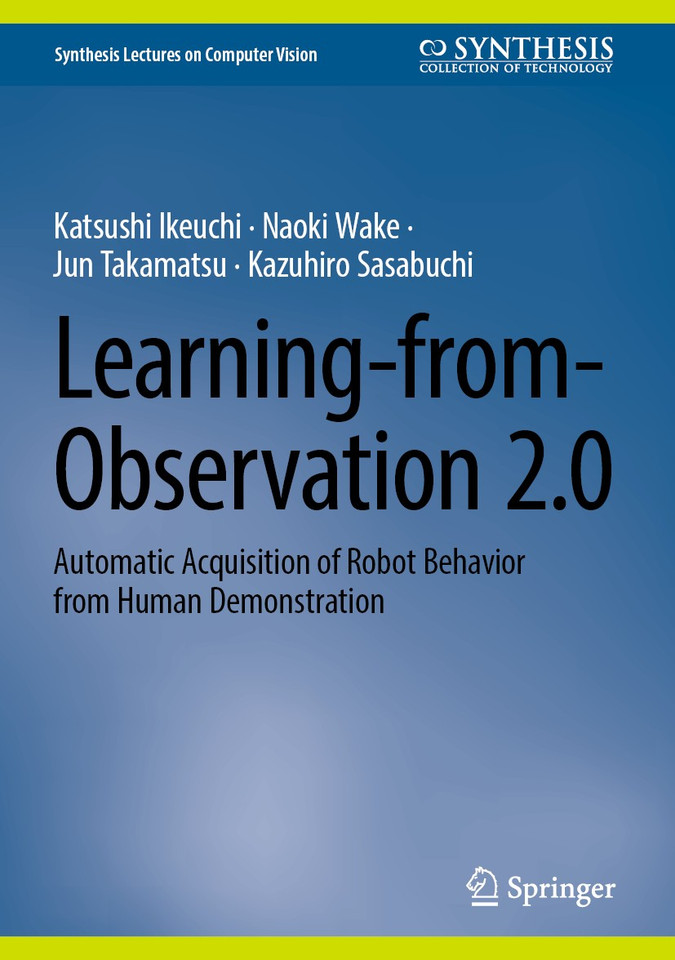
Learning-from-Observation 2.0: Automatic Acquisition of Robot Behavior from Human Demonstration (Synthesis Lectures on Computer Vision)
by Katsushi Ikeuchi, Naoki Wake, Jun Takamatsu and Kazuhiro Sasabuchi
$39.59 / copy at 25+ copies As low as $38.69 at 100+Your best volume price
Total $989.75
Format
The more copies, the less each one costs
Applied automatically in your cart. No code needed.
Turn this order into a program
Groups that order in bulk often pair the copies with something more. We handle the extras so you don't have to.
Bookplates, tipped-in pages, belly bands or author signatures. Hardcovers only, subject to publisher approval.
Customization options Ship to every readerOne address, many sites or individual recipients' homes, in the US and abroad.
Fulfillment options Pair it with a branded journalJournals with your logo or each reader's name, for the same group.
Branded journals Bring in a speaker
BookPal is partnering with Talezo to help you find and book authors, speakers and performers for your event.
BookPal × TalezoLearning-from-Observation 2.0
This book presents recent breakthroughs in the field of Learning-from-Observation (LfO) resulting from advancement in large language models (LLM) and reinforcement learning (RL) and positions it in the context of historical developments in the area. LfO involves observing human behaviors and generating robot actions that mimic these behaviors. While LfO may appear similar, on the surface, to Imitation Learning (IL) in the machine learning community and Programing-by-Demonstration (PbD) in the robotics community, a significant difference lies in the fact that these methods directly imitate human hand movements, whereas LfO encodes human behaviors into the abstract representations and then maps these representations onto the currently available hardware (individual body) of the robot, thus indirectly mimicking them. This indirect imitation allows for absorbing changes in the surrounding environment and differences in robot hardware. Additionally, by passing through this abstract representation, filtering can occur, distinguishing between important and less important aspects of human behavior, enabling imitation with fewer demonstrations and less demanding demonstrations. The authors have been researching the LfO paradigm for the past decade or so. Previously, the focus was primarily on designing necessary and sufficient task representations to define specific task domains such as assembly of machine parts, knot-tying, and human dance movements. Recent advancements in Generative Pre-trained Transformers (GPT) and RL have led to groundbreaking developments in methods to obtain and map these abstract representations. By utilizing GPT, the authors can automatically generate abstract representations from videos, and by employing RL-trained agent libraries, implementing robot actions becomes more feasible.
The book, Learning-from-Observation 2.0: Automatic Acquisition of Robot Behavior from Human Demonstration (Synthesis Lectures on Computer Vision) [Bulk, Wholesale, Quantity] ISBN#9783032034441 in Hardcover by Katsushi Ikeuchi, Naoki Wake, Jun Takamatsu, Kazuhiro Sasabuchi may be ordered in bulk quantities. Minimum starts at 25 copies. Availability based on publisher status and quantity being ordered.
Details
- Publisher
- Springer Nature Switzerland
- Authors
- Katsushi Ikeuchi, Naoki Wake, Jun Takamatsu, Kazuhiro Sasabuchi
- Format
- Hardcover
- Published
- Nov 2, 2025
- ISBN-13
- 9783032034441
- Pages
- 204
- Printing
- Printed on demand
Learning-from-Observation 2.0 in bulk: pricing
Volume pricing applies automatically in your cart. No codes, no account needed.
| Copies | Price per copy | You save |
|---|---|---|
| 25 – 49 | $39.59 | 12% off list |
| 50 – 99 | $39.14 | 13% off list |
| 100+ | $38.69 | 14% off list |
Popular for
A copy for every member, on one order.
A book for every attendee, delivered to your venue.
For clients, staff, members or volunteers.
How fast can I get copies of Learning-from-Observation 2.0?
This title is printed on demand, so it needs production time before it ships. Need them by a specific date? Request a quote and we'll confirm timing before you pay.
Can you ship to several locations or people's homes?
Yes. We ship in bulk to one address, to multiple sites, or to individual recipients, in the US and internationally. See fulfillment options.
Can I get a formal quote for approval before ordering?
Yes. Request a quote and we'll send a PDF you can forward for approval.
Do you accept purchase orders and tax-exempt orders?
Yes. We accept purchase orders upon approval, as well as cards, PayPal, ACH, wire transfers and checks. BookPal is a tax-exempt supplier in all 50 states. See purchase orders and sales tax exemption.
What if I find a lower price?
Send us the link. We match prices from other bulk booksellers and distributors on a new copy in the same edition, available to ship in the quantity you need. Clearance sales and pricing errors are the exception, and we'll tell you quickly if that's the case. Start a price match.
Write a Review
Learning-from-Observation 2.0: Automatic Acquisition of Robot Behavior from Human Demonstration (Synthesis Lectures on Computer Vision)
Groups also order


A colleague asked you to approve this order
Your quote list
Add books as you browse, then request one quote for all of them.