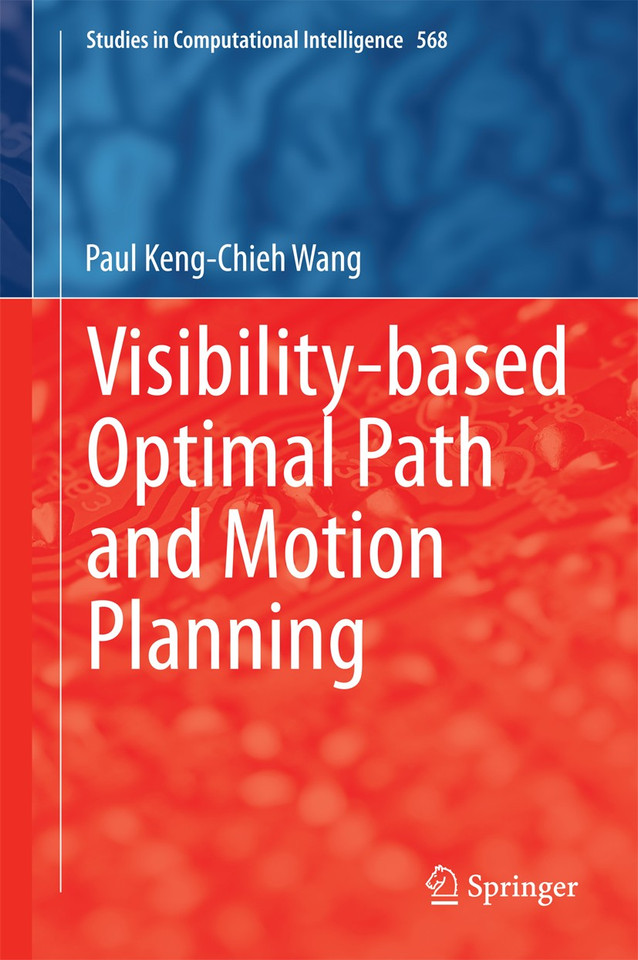
Visibility-based Optimal Path and Motion Planning (Studies in Computational Intelligence #568)
From $96.79 / copy at 25+ copies; lower per-copy prices at higher quantities (see Volume pricing) As low as $94.59 at 100+
Total $2,419.75
Format
The more copies, the less each one costs
Applied automatically in your cart. No code needed.
Turn this order into a program
Groups that order together often pair the copies with something more. We handle the extras so you don't have to.
Bookplates, tipped-in pages, belly bands or author signatures. Subject to publisher approval.
Customization options Ship to every readerOne address, many sites or individual recipients' homes, in the US and abroad.
Fulfillment options Pair it with a branded journalJournals with your logo or each reader's name, for the same group.
Branded journals Bring in a speaker
BookPal is partnering with Talezo to help you find and book authors, speakers and performers for your event.
BookPal × TalezoVisibility-based Optimal Path and Motion Planning (Studies in Computational Intelligence #568)
This monograph deals with various visibility-based path and motion planning problems motivated by real-world applications such as exploration and mapping planetary surfaces, environmental surveillance using stationary or mobile robots, and imaging of global air/pollutant circulation. The formulation and solution of these problems call for concepts and methods from many areas of applied mathematics including computational geometry, set-covering, non-smooth optimization, combinatorial optimization and optimal control. Emphasis is placed on the formulation of new problems and methods of approach to these problems. Since geometry and visualization play important roles in the understanding of these problems, intuitive interpretations of the basic concepts are presented before detailed mathematical development. The development of a particular topic begins with simple cases illustrated by specific examples, and then progresses forward to more complex cases.
The intended readers of this monograph are primarily students and researchers in engineering, computer science and applied mathematics. An understanding of the mathematical development of the main results requires only basic knowledge of mathematical analysis, control, and optimization theories. Some exercises with various degrees of difficulty are provided at the end of the main chapters. The material presented here may serve as a portion of an introductory course or seminar on visibility-based optimal path and motion planning problems with the objective of stimulating interest and further studies in this relatively new area.
Details
- Publisher
- Springer International Publishing
- Author
- Paul Keng-Chieh Wang
- Format
- Hardcover
- Published
- Aug 27, 2014
- ISBN-13
- 9783319097787
- Pages
- 198
- Printing
- Printed on demand
Visibility-based Optimal Path and Motion Planning (Studies in Computational Intelligence #568) for groups: pricing
Volume pricing applies automatically in your cart. No codes, no account needed.
| Copies | Price per copy | You save |
|---|---|---|
| 25 – 49 | $96.79 | 12% off list |
| 50 – 99 | $95.69 | 13% off list |
| 100+ | $94.59 | 14% off list |
Popular for
A copy for every member, on one order.
A book for every attendee, delivered to your venue.
For clients, staff, members or volunteers.
Where can I buy 100 copies of Visibility-based Optimal Path and Motion Planning?
BookPal sells Visibility-based Optimal Path and Motion Planning in quantity. At 100 copies the price is $94.59 a copy, against a list price of $109.99, and the cart applies the volume tier automatically. Free shipping on most orders over $95 in the contiguous US. A specialist can quote a larger or mixed order.
- New books only, straight from the publisher
- Volume prices apply automatically in the cart, with no code needed
- Order at least 10 business days before you need the books (11 from mid-November through December)
What does Visibility-based Optimal Path and Motion Planning (Studies in Computational Intelligence #568) cost when I buy for a group?
Volume pricing applies automatically in your cart, with no code needed. Price per copy: 25 to 49 copies, $96.79 (12% off list); 50 to 99 copies, $95.69 (13% off list); 100+ copies, $94.59 (14% off list). Need a different quantity, or a quote to forward for approval? Ask a specialist and we will confirm pricing before you pay.
How fast can I get copies of Visibility-based Optimal Path and Motion Planning (Studies in Computational Intelligence #568)?
This title is printed on demand, so it needs production time before it ships. Need them by a specific date? Request a quote and we'll confirm timing before you pay.
Can you ship to several locations or people's homes?
Yes. We ship group orders to one address, to multiple sites, or to individual recipients, in the US and internationally. See fulfillment options.
Can I get a formal quote for approval before ordering?
Yes. Request a quote and we'll send a PDF you can forward for approval.
Do you accept purchase orders and tax-exempt orders?
Yes. We accept purchase orders upon approval, as well as cards, PayPal, ACH, wire transfers and checks. BookPal is a tax-exempt supplier in all 50 states. See purchase orders and sales tax exemption.
What if I find a lower price?
Send us the link. We match prices from other booksellers and distributors on a new copy in the same edition, available to ship in the quantity you need. Clearance sales and pricing errors are the exception, and we'll tell you quickly if that's the case. Start a price match.
Write a Review
Visibility-based Optimal Path and Motion Planning (Studies in Computational Intelligence #568)
Groups also order


A colleague asked you to approve this order
Your quote list
Add books as you browse, then request one quote for all of them.