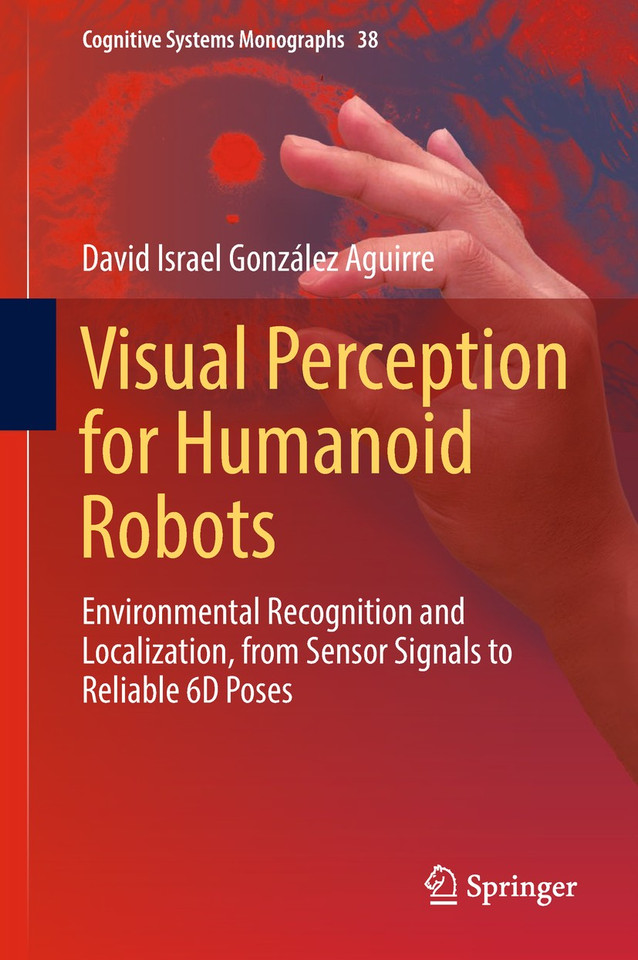
Visual Perception for Humanoid Robots: Environmental Recognition and Localization, from Sensor Signals to Reliable 6D Poses (Cognitive Systems Monographs #38)
by David Israel González Aguirre
From $96.79 / copy at 25+ copies; lower per-copy prices at higher quantities (see Volume pricing) As low as $94.59 at 100+
Total $2,419.75
Format
The more copies, the less each one costs
Applied automatically in your cart. No code needed.
Turn this order into a program
Groups that order together often pair the copies with something more. We handle the extras so you don't have to.
Bookplates, tipped-in pages, belly bands or author signatures. Subject to publisher approval.
Customization options Ship to every readerOne address, many sites or individual recipients' homes, in the US and abroad.
Fulfillment options Pair it with a branded journalJournals with your logo or each reader's name, for the same group.
Branded journals Bring in a speaker
BookPal is partnering with Talezo to help you find and book authors, speakers and performers for your event.
BookPal × TalezoVisual Perception for Humanoid Robots
• Active Sensing: Robust probabilistic methods for optimal, high dynamic range image acquisition are suitable for use with inexpensive cameras. This enables ideal sensing in arbitrary environmental conditions encountered in human-centric spaces. The book quantitatively shows the importance of equipping robots with dependable visual sensing.
• Feature Extraction & Recognition: Parameter-free, edge extraction methods based on structural graphs enable the representation of geometric primitives effectively and efficiently. This is done by eccentricity segmentation providing excellent recognition even on noisy & low-resolution images. Stereoscopic vision, Euclidean metric and graph-shape descriptors are shown to be powerful mechanisms for difficult recognition tasks.
• Global Self-Localization & Depth Uncertainty Learning: Simultaneous feature matching for global localization and 6D self-pose estimation are addressed by a novel geometric and probabilistic concept using intersection of Gaussian spheres. The path from intuition to the closed-form optimal solution determining the robot location is described, including a supervised learning method for uncertainty depth modeling based on extensive ground-truth training data from a motion capture system.
The methods and experiments are presented in self-contained chapters with comparisons and the state of the art. The algorithms were implemented and empirically evaluated on two humanoid robots: ARMAR III-A & B. The excellent robustness, performance and derived results received an award at the IEEE conference on humanoid robots and the contributions have been utilized for numerous visual manipulation tasks with demonstration at distinguished venues such as ICRA, CeBIT, IAS, and Automatica.
Details
- Publisher
- Springer International Publishing
- Author
- David Israel González Aguirre
- Format
- Hardcover
- Published
- Sep 11, 2018
- ISBN-13
- 9783319978390
- Pages
- 220
- Printing
- Printed on demand
Visual Perception for Humanoid Robots for groups: pricing
Volume pricing applies automatically in your cart. No codes, no account needed.
| Copies | Price per copy | You save |
|---|---|---|
| 25 – 49 | $96.79 | 12% off list |
| 50 – 99 | $95.69 | 13% off list |
| 100+ | $94.59 | 14% off list |
Popular for
A copy for every member, on one order.
A book for every attendee, delivered to your venue.
For clients, staff, members or volunteers.
Where can I buy 100 copies of Visual Perception for Humanoid Robots?
BookPal sells Visual Perception for Humanoid Robots in quantity. At 100 copies the price is $94.59 a copy, against a list price of $109.99, and the cart applies the volume tier automatically. Free shipping on most orders over $95 in the contiguous US. A specialist can quote a larger or mixed order.
- New books only, straight from the publisher
- Volume prices apply automatically in the cart, with no code needed
- Order at least 10 business days before you need the books (11 from mid-November through December)
What does Visual Perception for Humanoid Robots cost when I buy for a group?
Volume pricing applies automatically in your cart, with no code needed. Price per copy: 25 to 49 copies, $96.79 (12% off list); 50 to 99 copies, $95.69 (13% off list); 100+ copies, $94.59 (14% off list). Need a different quantity, or a quote to forward for approval? Ask a specialist and we will confirm pricing before you pay.
How fast can I get copies of Visual Perception for Humanoid Robots?
This title is printed on demand, so it needs production time before it ships. Need them by a specific date? Request a quote and we'll confirm timing before you pay.
Can you ship to several locations or people's homes?
Yes. We ship group orders to one address, to multiple sites, or to individual recipients, in the US and internationally. See fulfillment options.
Can I get a formal quote for approval before ordering?
Yes. Request a quote and we'll send a PDF you can forward for approval.
Do you accept purchase orders and tax-exempt orders?
Yes. We accept purchase orders upon approval, as well as cards, PayPal, ACH, wire transfers and checks. BookPal is a tax-exempt supplier in all 50 states. See purchase orders and sales tax exemption.
What if I find a lower price?
Send us the link. We match prices from other booksellers and distributors on a new copy in the same edition, available to ship in the quantity you need. Clearance sales and pricing errors are the exception, and we'll tell you quickly if that's the case. Start a price match.
Write a Review
Visual Perception for Humanoid Robots: Environmental Recognition and Localization, from Sensor Signals to Reliable 6D Poses (Cognitive Systems Monographs #38)
Groups also order


A colleague asked you to approve this order
Your quote list
Add books as you browse, then request one quote for all of them.